RL Agent
My first reinforcement learning agent, trained in a 2D physics-based environment
- Year
- 2025
- Role
- Creator, Developer
- Built with
- Python · Pytorch · Machine learning
Architecture
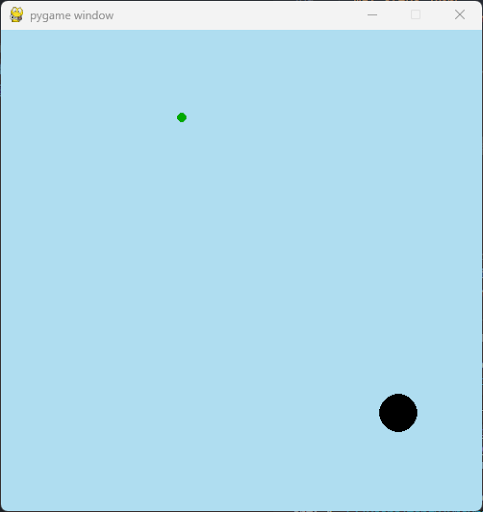
In this project, I created a 2D low-friction environment for an agent to navigate. The environment contains a goal point; each time the agent touches the goal, the goal respawns in a new random location. The agent must learn to reach as many goals as possible within a defined time limit.
Each timestep, the agent outputs a distribution for the four possible actions (up, down, left, and right). An action is randomly sampled, causing the agent to accelerate in that direction.
The agent is rewarded for approaching and reaching the goal; it is penalized for moving away from the goal, or falling out of bounds. After each fixed-length episode, the app calculates the discounted returns for each action the agent took.
These returns are used to train the model's baseline network to predict expected return given a particular action in a particular state. The agent's behavior is updated by reinforcing or discouraging actions depending on their overall performance when compared to baseline predictions.
Libraries used in this project:
- Gymnasium for the custom environment
- Pytorch for neural net training
- Pygame for environment rendering
- Matplotlib for data visualization
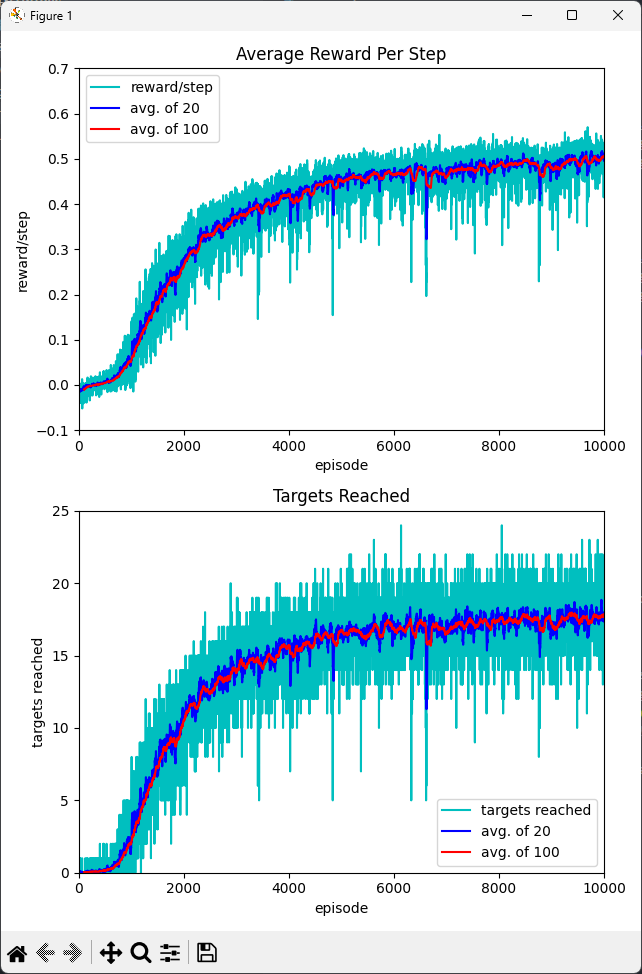
Results:
Example environment render:
Training graphs: